
Independent project · The Pennington School · 2025
From point clouds to passing cars.LiDAR Traffic-Monitoring System
I built a C++ pipeline that groups LiDAR points into vehicles and tracks them over time to estimate traffic speed.
- Tools
- C++ & Linux
- Method
- 3D breadth-first search
- Setting
- Eight-lane roadway
From points to vehicles
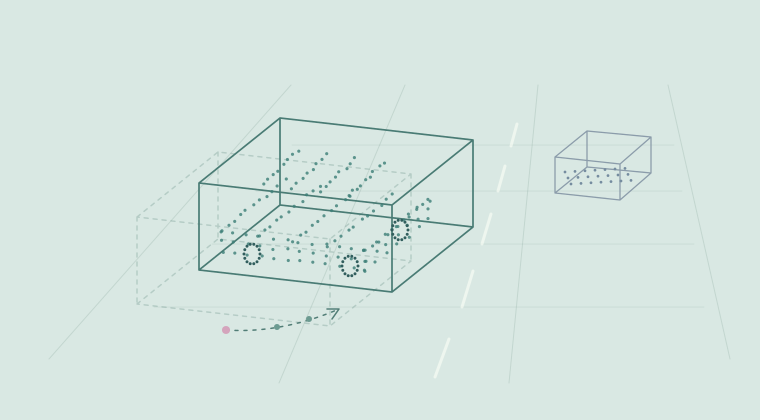
I used a sensitivity-tuned, three-dimensional breadth-first search to group nearby LiDAR points and build bounding boxes around the resulting vehicle clusters.
Tracking motion
The pipeline tracks the boxes across frames. I estimated vehicle speed from three-dimensional displacement over elapsed time to support traffic-flow analysis.
Guidance
I worked on the project while at The Pennington School, with guidance from Gang Zhou, a Principal Software Engineer at Seyond.